Skip to content
www.H-U-M-A-N-O-I-D.com

The most valuable Humanoid domain name in the world

THIS DOMAIN IS FOR SALE

WORLDWIDE THIS IS THE MOST SOUGHT AFTER DOMAIN IN THE INDUSTRY

Primary Menu
  • About us
  • Privacy Policy
Humanoid Shop coming soon
  • Home
  • 2026
  • January
  • 1
  • Enhancing Robot Task and Motion Planning Efficiency through Geometric Reasoning-Based Learning
  • Humanoids and AI

Enhancing Robot Task and Motion Planning Efficiency through Geometric Reasoning-Based Learning

The humans behind H-u-m-a-n-o-i-d.com January 1, 2026 2 min read
Enhancing Robot Task and Motion Planning Efficiency through Geometric Reasoning-Based Learning

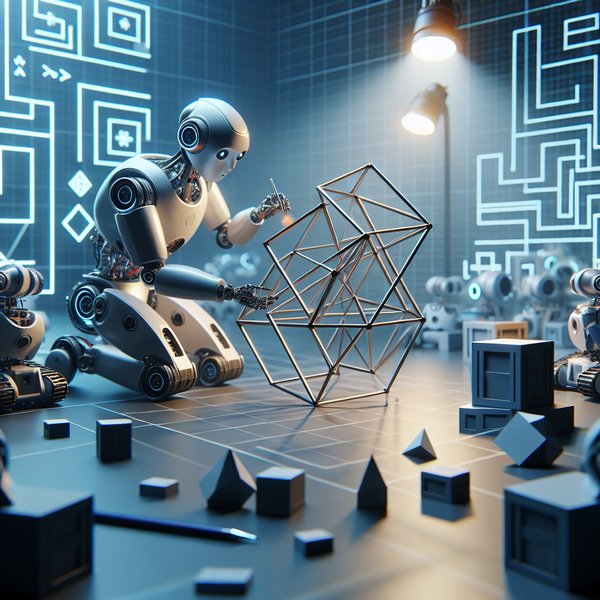
This thesis presents a novel learning-based framework designed to enhance the efficiency and scalability of Task and Motion Planning (TAMP) for robotic manipulation tasks within cluttered and intricate environments. Conventional TAMP approaches encounter significant hurdles arising from the high computational burden of repetitive geometric feasibility assessments and the exponential growth of the search space, particularly in multi-robot scenarios. In response to these challenges, the thesis puts forth two deep learning models: AGFPNet, which predicts the feasibility of manipulation actions to minimize reliance on geometric planners, and GRN, which employs graph neural networks and scene graphs to offer interpretable and adaptable feasibility predictions, including insights into the causes of action failure.

Furthermore, these models are expanded to accommodate collaborative multi-robot scenarios and intricate, mesh-shaped objects. Leveraging these models, the thesis suggests a multi-robot TAMP algorithm guided by feasibility insights, which seamlessly integrates learned geometric reasoning into a search-based planner. This integration facilitates expedited search space exploration by prioritizing promising actions while avoiding unfeasible ones. Additionally, a new informed backtracking mechanism is introduced, utilizing predicted infeasibility causes to refine planning constraints and heuristic cost functions towards the objective.

Extensive experiments showcased the efficacy of the proposed approach in accelerating planning processes, enhancing scalability, and preserving generalizability, even when operating in highly cluttered or expansive environments. The outcomes of these experiments demonstrated the ability of the proposed method to successfully tackle complex manipulation tasks with extended planning horizons in challenging, cluttered environments, while significantly reducing planning times.

About the Author

The humans behind H-u-m-a-n-o-i-d.com

Author

Visit Website View All Posts

Post navigation

Previous: Human-in-the-Loop Robot Learning in Unstructured Environments
Next: Python Adventures for Young Coders: Explore the World of Programming

Related News

Neuron AI: The Brain of the Physical World
2 min read
  • Humanoids and AI

Neuron AI: The Brain of the Physical World

The humans behind H-u-m-a-n-o-i-d.com October 19, 2026 0
Amap Launches Upgraded ABot System for AI Robots
2 min read
  • Humanoids and AI

Amap Launches Upgraded ABot System for AI Robots

The humans behind H-u-m-a-n-o-i-d.com October 8, 2026 0
Blockly Pro Enhances Coding Experience with Python Integration
2 min read
  • Humanoids and AI

Blockly Pro Enhances Coding Experience with Python Integration

The humans behind H-u-m-a-n-o-i-d.com October 7, 2026 0

Recent Posts

  • Optimizing Design for Social Robots: Enhancing Emotional Appeal through Face and Voice Considerations
  • Neuron AI: The Brain of the Physical World
  • WeTouch Technology Expands into Robot Human-Machine Interaction Sector with Anhui Moke Robot Partnership
  • Advancing Robotics, AI, and Computer Vision to Elevate Customer Experience (CX)
  • UBTECH Unveils New Factory for Producing 10,000 Humanoid Robots Annually

Recent Comments

No comments to show.

Archives

  • October 2026
  • September 2026
  • August 2026
  • July 2026
  • June 2026
  • May 2026
  • April 2026
  • March 2026
  • February 2026
  • January 2026
  • December 2025

Categories

  • General
  • Humanoid Robots
  • Humanoids and AI
  • Humanoids and Humans
  • Humanoids Development
  • Humanoids for Sale
  • Uncategorized

You may have missed

Optimizing Design for Social Robots: Enhancing Emotional Appeal through Face and Voice Considerations
3 min read
  • Humanoids and Humans

Optimizing Design for Social Robots: Enhancing Emotional Appeal through Face and Voice Considerations

The humans behind H-u-m-a-n-o-i-d.com October 20, 2026 0
Neuron AI: The Brain of the Physical World
2 min read
  • Humanoids and AI

Neuron AI: The Brain of the Physical World

The humans behind H-u-m-a-n-o-i-d.com October 19, 2026 0
WeTouch Technology Expands into Robot Human-Machine Interaction Sector with Anhui Moke Robot Partnership
2 min read
  • Humanoids and Humans

WeTouch Technology Expands into Robot Human-Machine Interaction Sector with Anhui Moke Robot Partnership

The humans behind H-u-m-a-n-o-i-d.com October 16, 2026 0
Advancing Robotics, AI, and Computer Vision to Elevate Customer Experience (CX)
2 min read
  • General

Advancing Robotics, AI, and Computer Vision to Elevate Customer Experience (CX)

The humans behind H-u-m-a-n-o-i-d.com October 16, 2026 0